Legacy example · Python · Version 1.0
Depth Anything V2
| Authors | Holoscan Team (NVIDIA) |
|---|---|
| Supported platforms | x86_64, aarch64 |
| Language | Python |
| Version | 1.0 |
| Compatibility | HSDK 2.8 |
| Contribution level | Level 2 · Quality code |
| Source | HoloHub |
Legacy HoloHub application
This application comes from HoloHub and was last tested with Holoscan SDK (HSDK) 2.8. It runs with the HoloHub CLI, ./holohub.
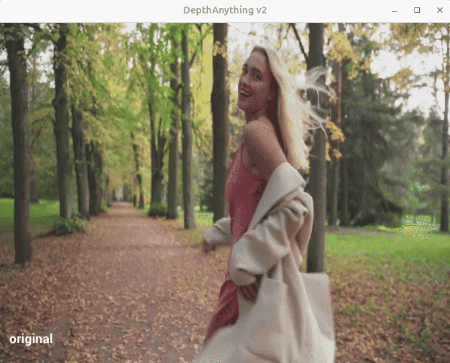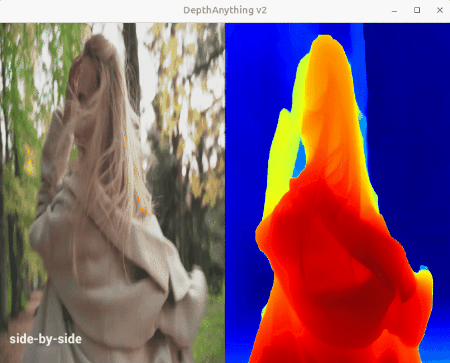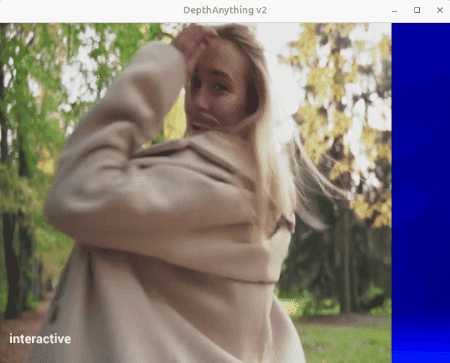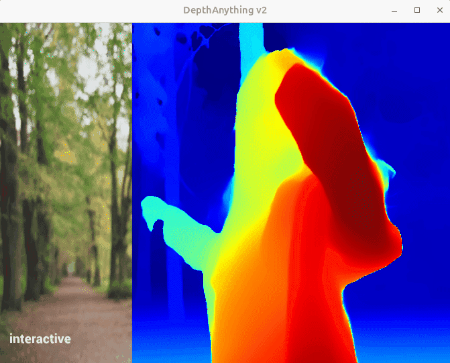
This application uses the Depth Anything V2 model for monocular depth estimation. Monocular Depth Estimation refers to the task of predicting the distance of objects in a scene from a single 2D image captured by a standard camera.
Model
This application uses the Depth Anything V2 model from DepthAnythingV2 for monocular depth estimation. The model is downloaded when building the Docker image.
NOTE: The user is responsible for checking if the model license is suitable for the intended purpose.
Data
This application downloads a pre-recorded video from Pexels when the application is built. Please review the license terms from Pexels.
NOTE: The user is responsible for ensuring the dataset license is suitable for the intended purpose.
Input
This app supports two different input options. If you have a v4l2 compatible device plugged into your machine such as a webcam, you can run this application with option 1. Otherwise you can run this application using a pre-recorded video with option 2.
- v4l2 compatible input device (default, see V4L2 Support below)
- pre-recorded video (see Video Replayer Support below)
To see the list of v4l2 devices connected to your machine, install v4l-utils if it's not already installed:
sudo apt-get install v4l-utils
Then run:
v4l2-ctl --list-devices
Run Instructions
V4L2 Support
This application supports v4l2 compatible devices as input. To run this application with your v4l2 compatible device, please plug in your input device and run:
./holohub run depth_anything_v2
By default, this application expects the input device to be mounted at /dev/video0. If this is not the case, update
applications/depth_anything_v2/depth_anything_v2.yaml file to set the corresponding input device before
running the application. You can also override the default input device on the command line by running:
./holohub run depth_anything_v2 --run-args="--video_device /dev/video0"
Video Replayer Support
If you don't have a v4l2 compatible device plugged in, you can also run this application on a pre-recorded video. To launch the application using the Video Stream Replayer as the input source, run:
./holohub run depth_anything_v2 --run-args="--source replayer"
Display Modes
This application has multiple display modes which you can toggle through using the left mouse button.
- original: output the original image from input source
- depth: output the color depthmap based on the depthmap returned from Depth Anything V2 model
- side-by-side: output a side-by-side view of the original image next to the color depthmap
- interactive: allow user
In interactive mode, the middle or right mouse button can be used to modify the ratio of original image vs color depthmap is shown.
Acknowledgement
This project is based on the following projects:
- Depth-Anything-V2 - Depth Anything V2
- depth-anything-tensorrt - Depth Anything TensorRT CLI
Known Issues
There is a known issue running this application on IGX w/ iGPU and on Jetson AGX (see #500). The workaround is to update the device to avoid picking up the libnvv4l2.so library.
cd /usr/lib/aarch64-linux-gnu/
ls -l libv4l2.so.0.0.999999
sudo rm libv4l2.so.0.0.999999
sudo ln -s libv4l2.so.0.0.0.0  libv4l2.so.0.0.999999